Kefan Wu at the wheel of Olin Electric Motorsports’ Formula SAE car on the test track.
ArduinoTIG weldingAutoCADTopology study SolidWorksMATLABFEACFD CNC millLatheWaterjetCarbon fiberTeam managementAI-assisted eng

Mechanical engineering/Olin ’28

KefanWu.

Leading 30
mechanical engineers
Mechanical Lead · Olin Electric Motorsports

Race-car systems.
Robotics. Real hardware.
Designed, built,
and tested.

01ProjectsShowing 16 of 16 projects

Built to work.

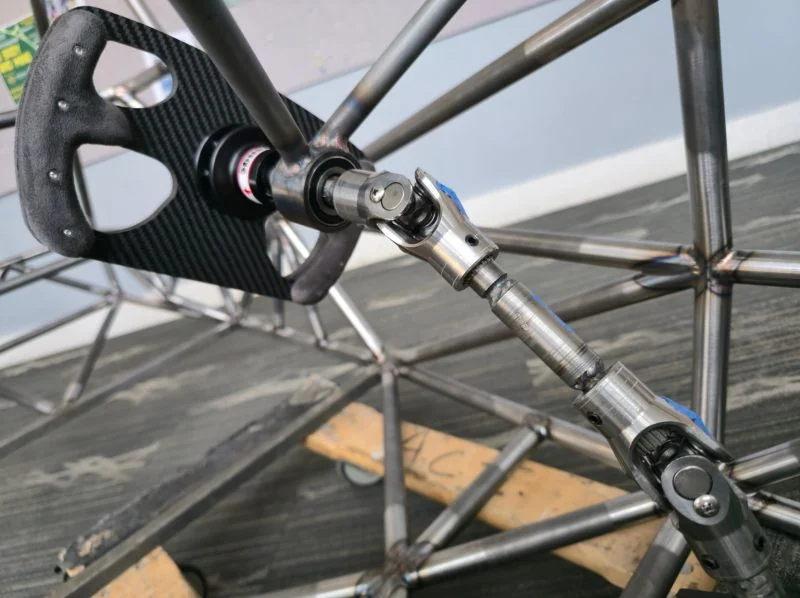
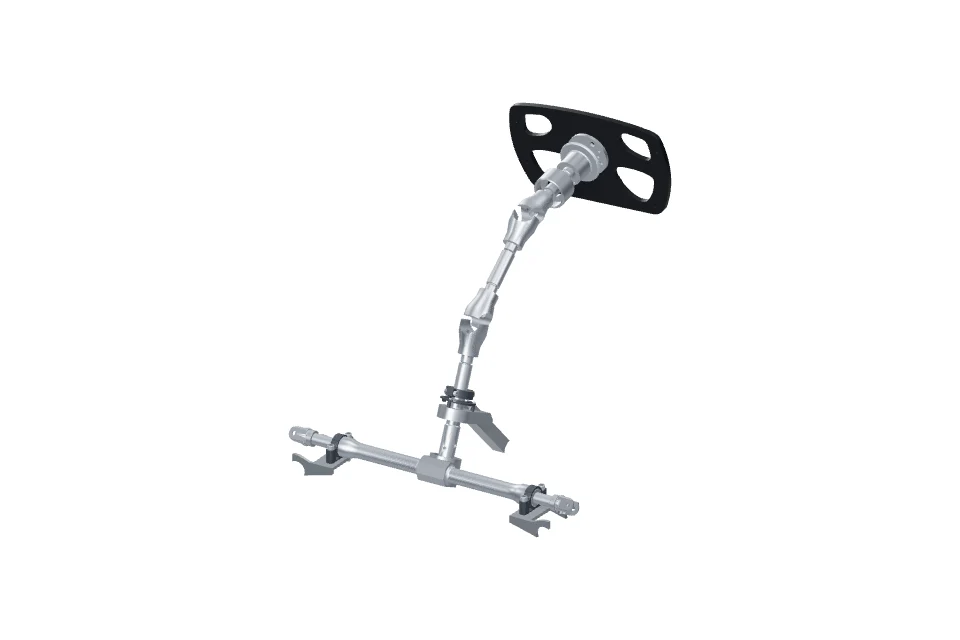
Steering wheel, column, universal joints and rack in their neutral position.

Mk.8 steering system

Olin Electric Motorsports · Design & fabrication

Closer driver reach; 0.9 kg removed from the bearing cages.

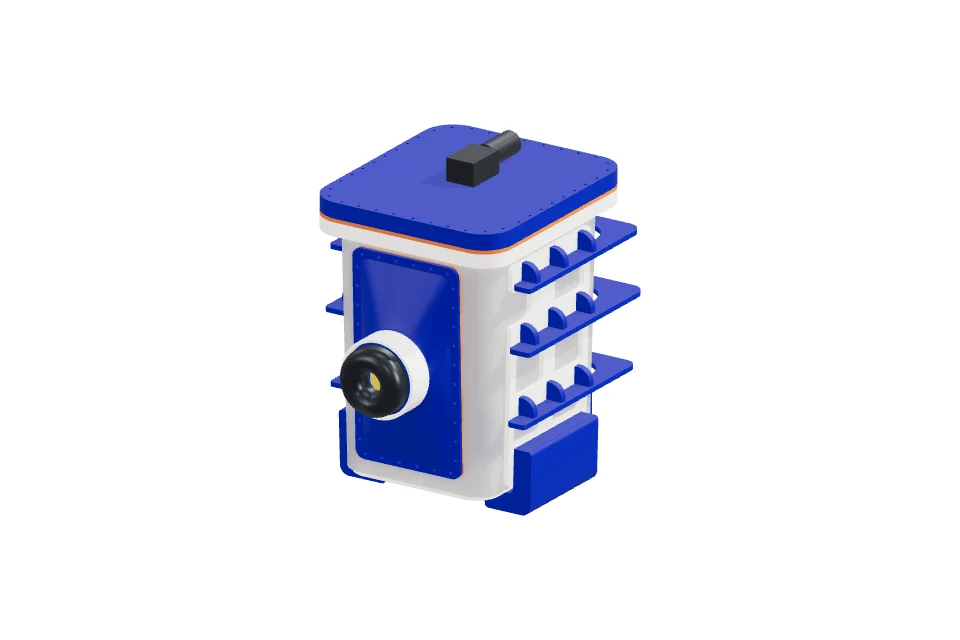
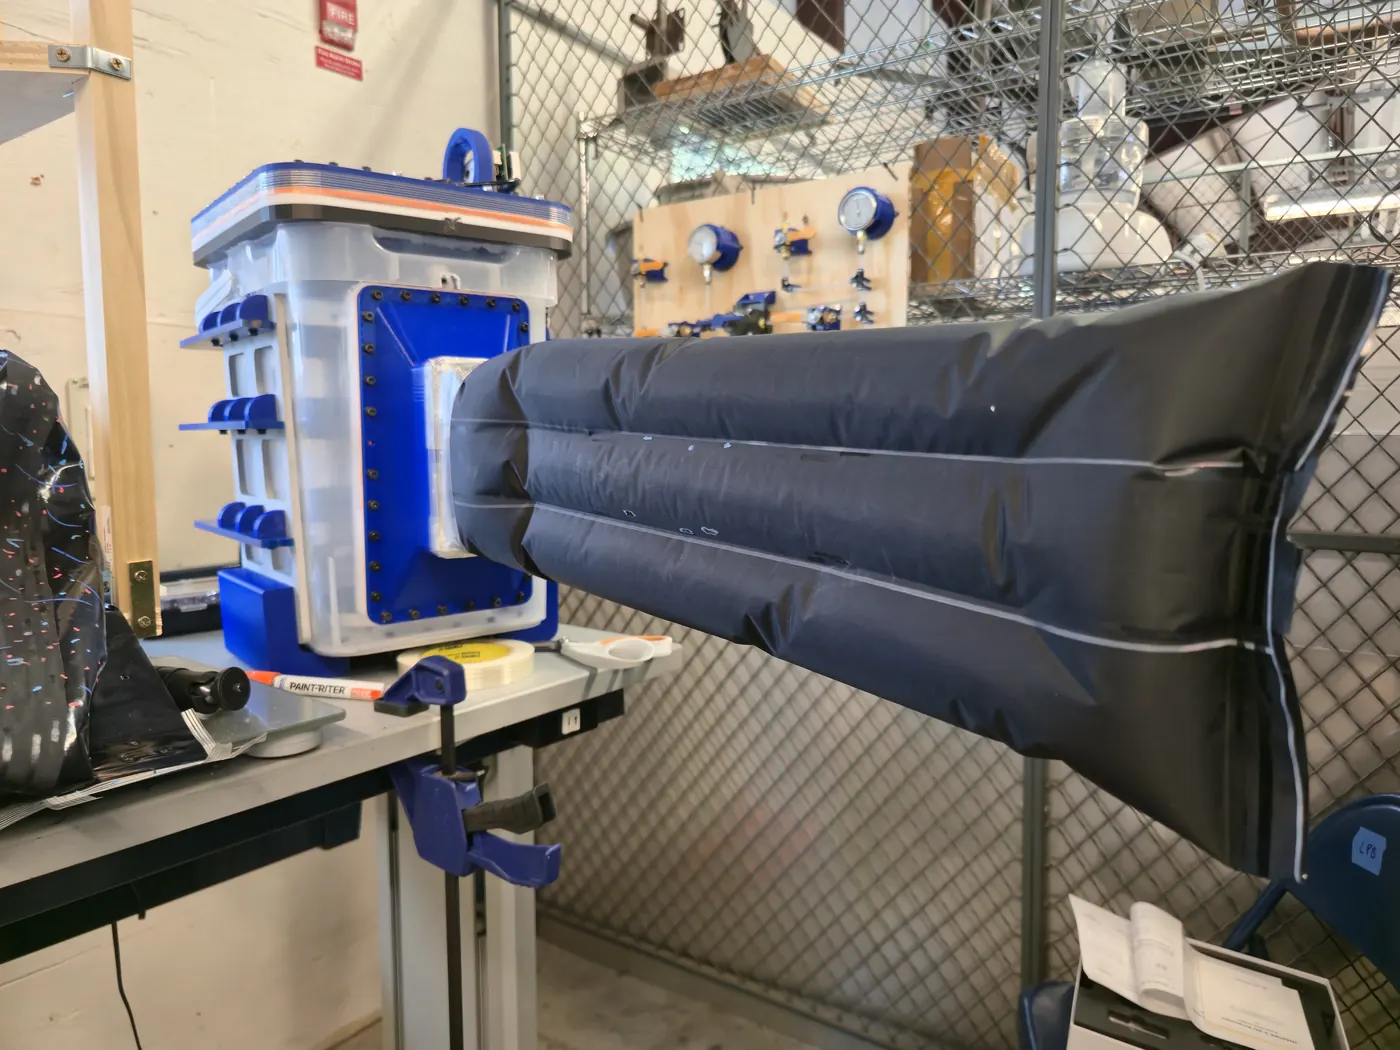
Vine robot pressure vessel with its translucent tube retracted.

Vine everting robot

Olin Vine Robotics Lab · Research assistant · 2026

Pressure-test failures drove reinforcement and a 45-run study.

Perforated cast-iron brake rotor before heating.

FSAE Racecar Brake

Olin Electric Motorsports · Individual project

Design review: 23% less rotor mass, 19% less inertia.
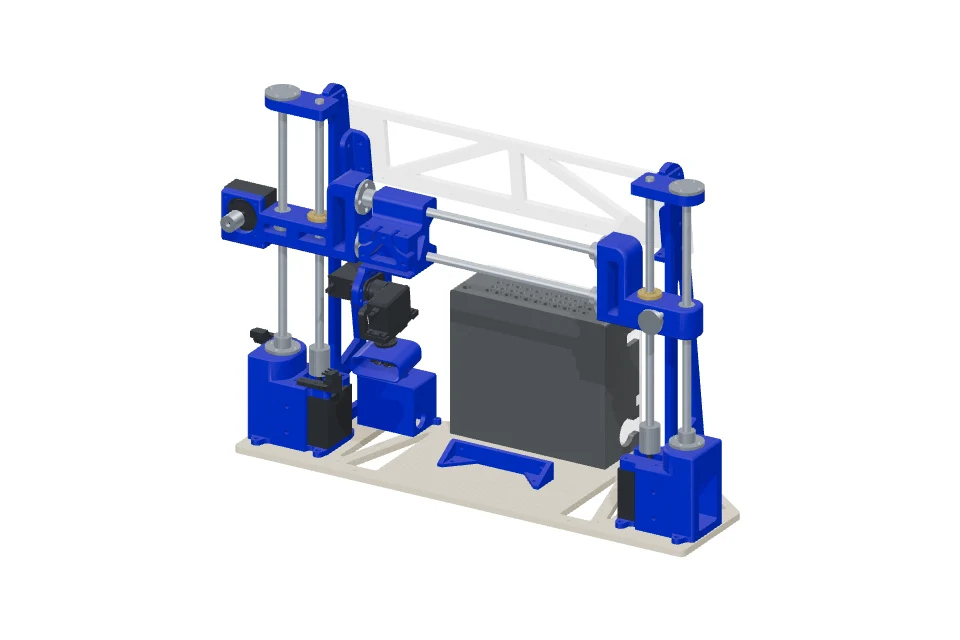
LiDAR scanner with blue printed mounts, guide rods and a plywood base.

LiDAR scanner

Olin PIE · Gantry & calibration

Gantry motion and calibration produced a 2,206-point scan.

Javelin airframe suspended above the studio floor with four propellers.

Javelin VTOL drone

Individual project · Airframe & integration

A built VTOL airframe working toward a 300 km/h target.

In progress

Charcoal fabric specimen held between silver grips before stretching.

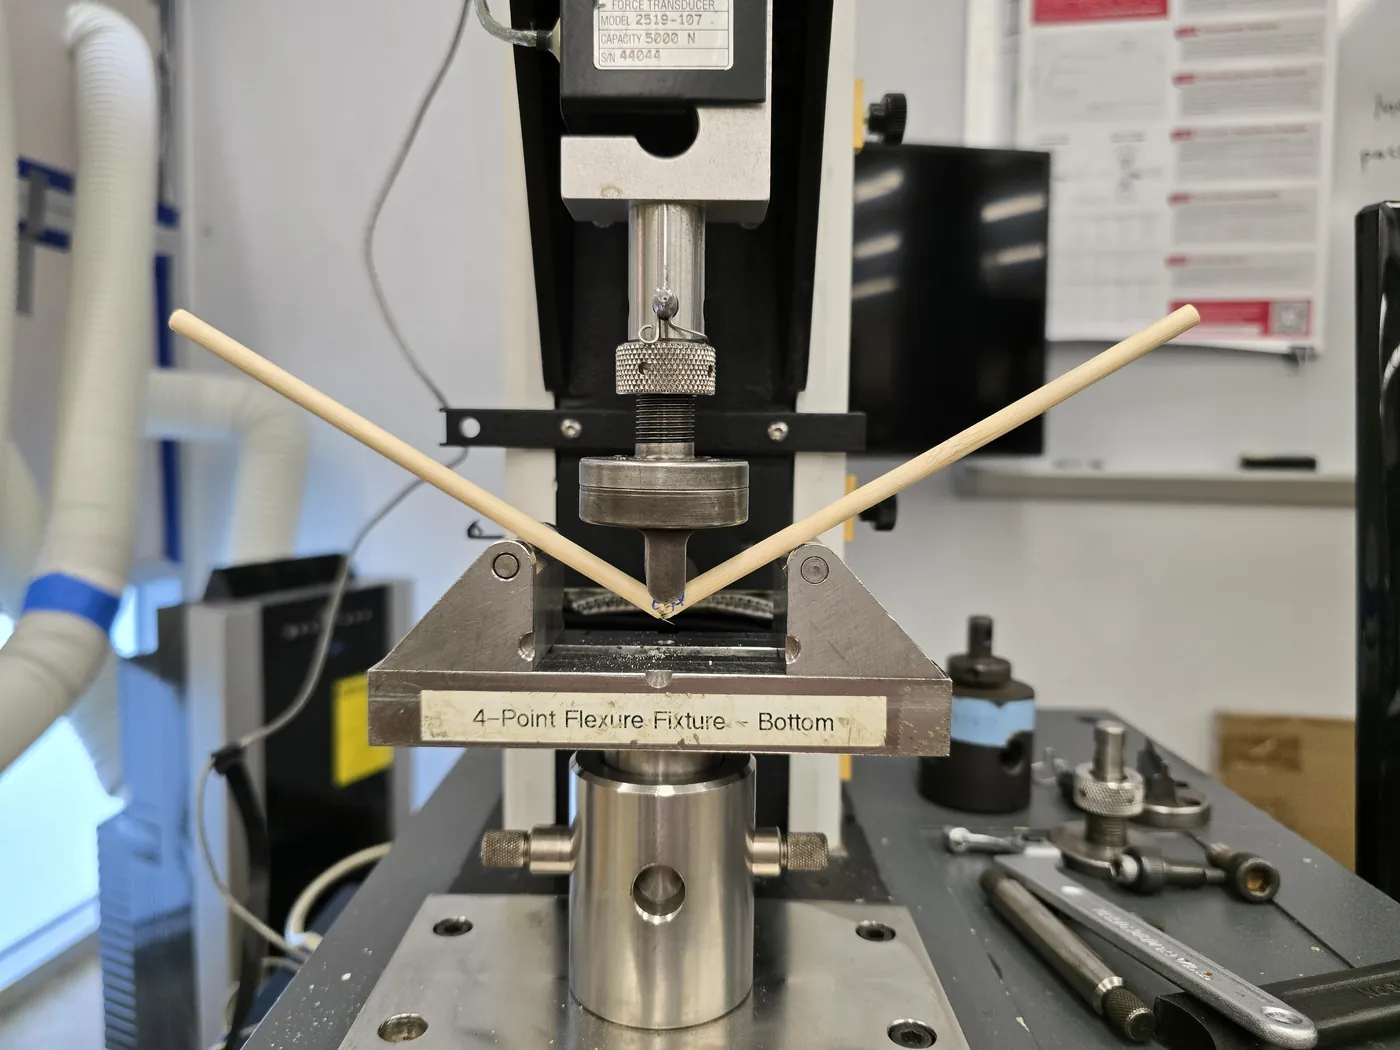
Material property testing

Olin Vine Robotics Lab · Instron testing

30 tensile specimens and 11 rods supplied measured stiffness.

Assembled AURA swerve module with its wheel, motors and metal structure.

AURA swerve drive

Autonomous luggage robot · Mechanical Engineer

200 lb payload target; 300 lb carried in testing.

Carbon-fiber seat layup at the beginning of the fabrication sequence.

Carbon fiber seat

Olin Electric Motorsports · Individual project

20-ply 3K twill shell with local patch plies; cured, demolded and trimmed.

Perforated 5052-H32 aluminum Mk.7 driver seat.

Mk.7 driver seat

Olin Electric Motorsports · Design & fabrication

Designed and fabricated the Mk.7 seat in 5052-H32 aluminum.

Pool Sniper launcher with its cue extended before retraction.

Pool Sniper

Team project · Cue & cue-base fabrication

Adjustable cue launcher, working after machining and fit revisions.

Line-following robot with orange wheels and a teal circuit board.

LineFollower robot

Olin PIE · Two-person team

33.6% lighter; 18 s lap against an under-15 s target.

Smelly perfume mixer with its white structure and steel guide rods.

Smelly

Formlabs hackathon · Gantry & actuator design

A 2.5-day gantry build exposed an actuator duty-cycle limit.

Finished Telecaster-style guitar at the start of its full rotation.

Telecaster guitar

Individual project · Woodworking & electronics

Raw walnut, CNC routing, and fixtures led to a playable guitar.

Separated guitar education kit before assembly.

Guitar education kit

Individual project · STEAM hardware

About $80 prototype cost; student trials shaped the kit.

Assembled FTC robot with an aluminum lift, red panels and mecanum wheels.

FTC robot

Pioneer Robotics FTC 12589 · Senior Mechanical Engineer · 2022–23

Cone-handling mechanisms for a Massachusetts Championship winning alliance.

02Leadership30 engineers. One race car.
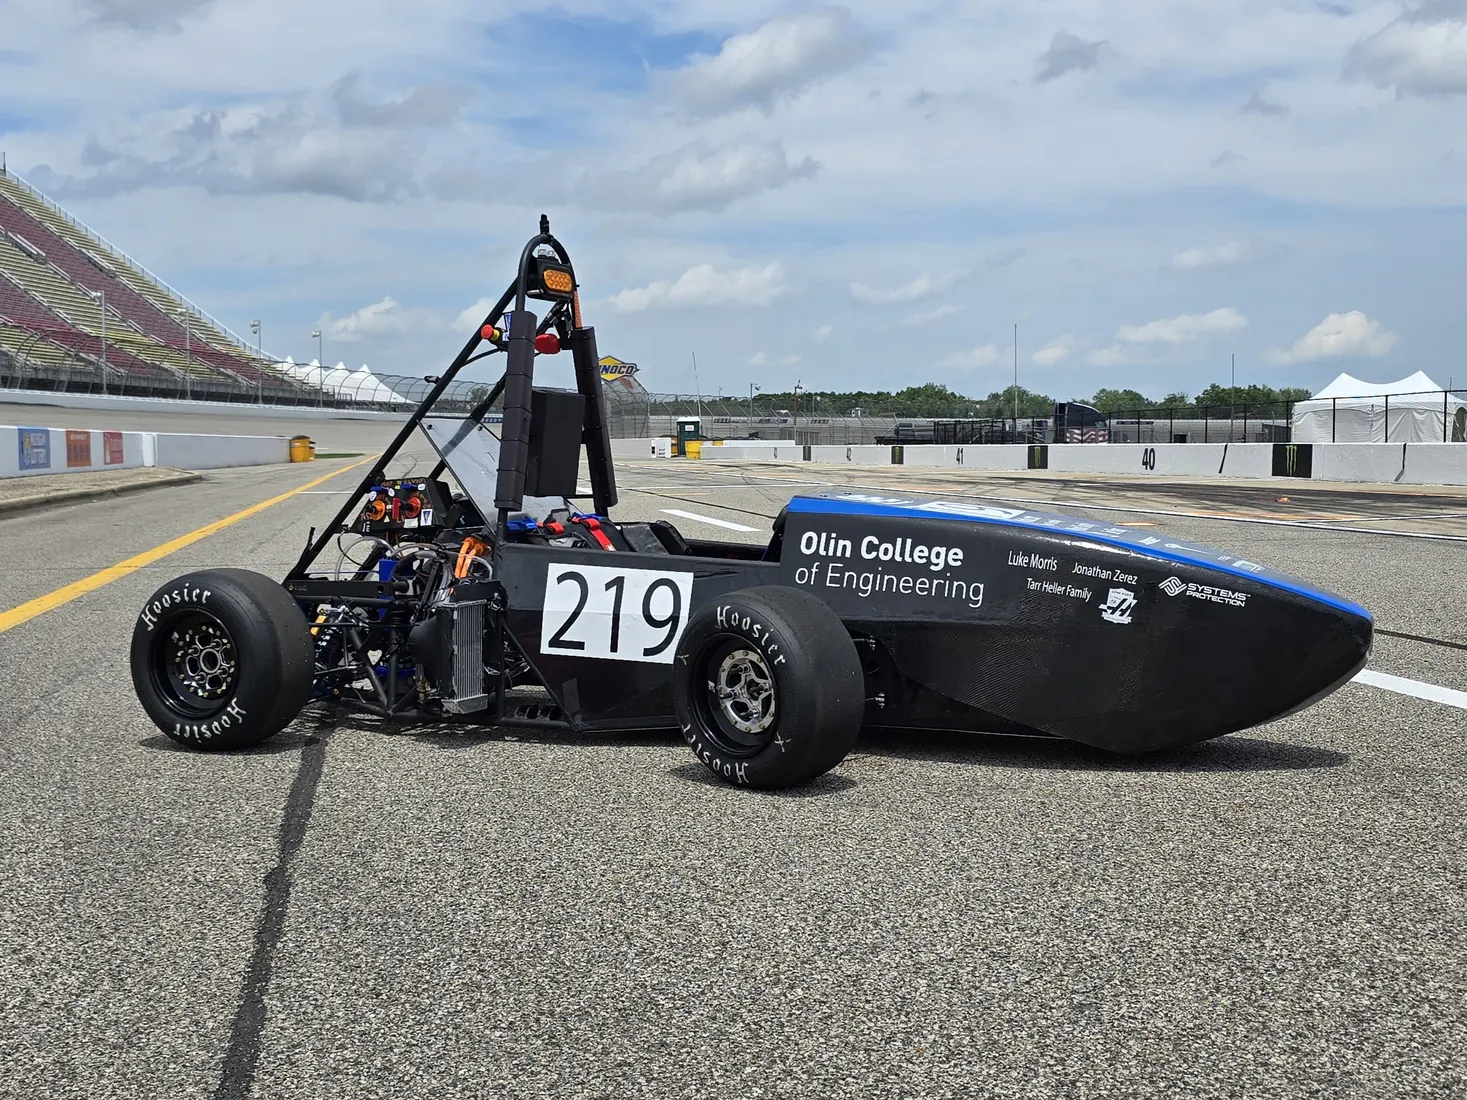
Olin Electric Motorsports Mk.7 race car, number 219, in a paddock setting
Olin Electric Motorsports · Mk.7

Engineer the system.
Enable the team.

I lead 30 mechanical engineers across four subteams, from design reviews and fabrication to vehicle integration. Previously, I led the cockpit: brakes, steering, and driver fit.

30Mechanical engineers

4Subteams

  1. 2024Engineer
  2. 2025Cockpit Lead
  3. 2026Mechanical Lead
Olin Electric Motorsports

3D StudioThe interactive portfolio

Step inside
my workshop.

Explore the space. Pick up a project. Look at the engineering from every angle.

Enter the 3D Studio
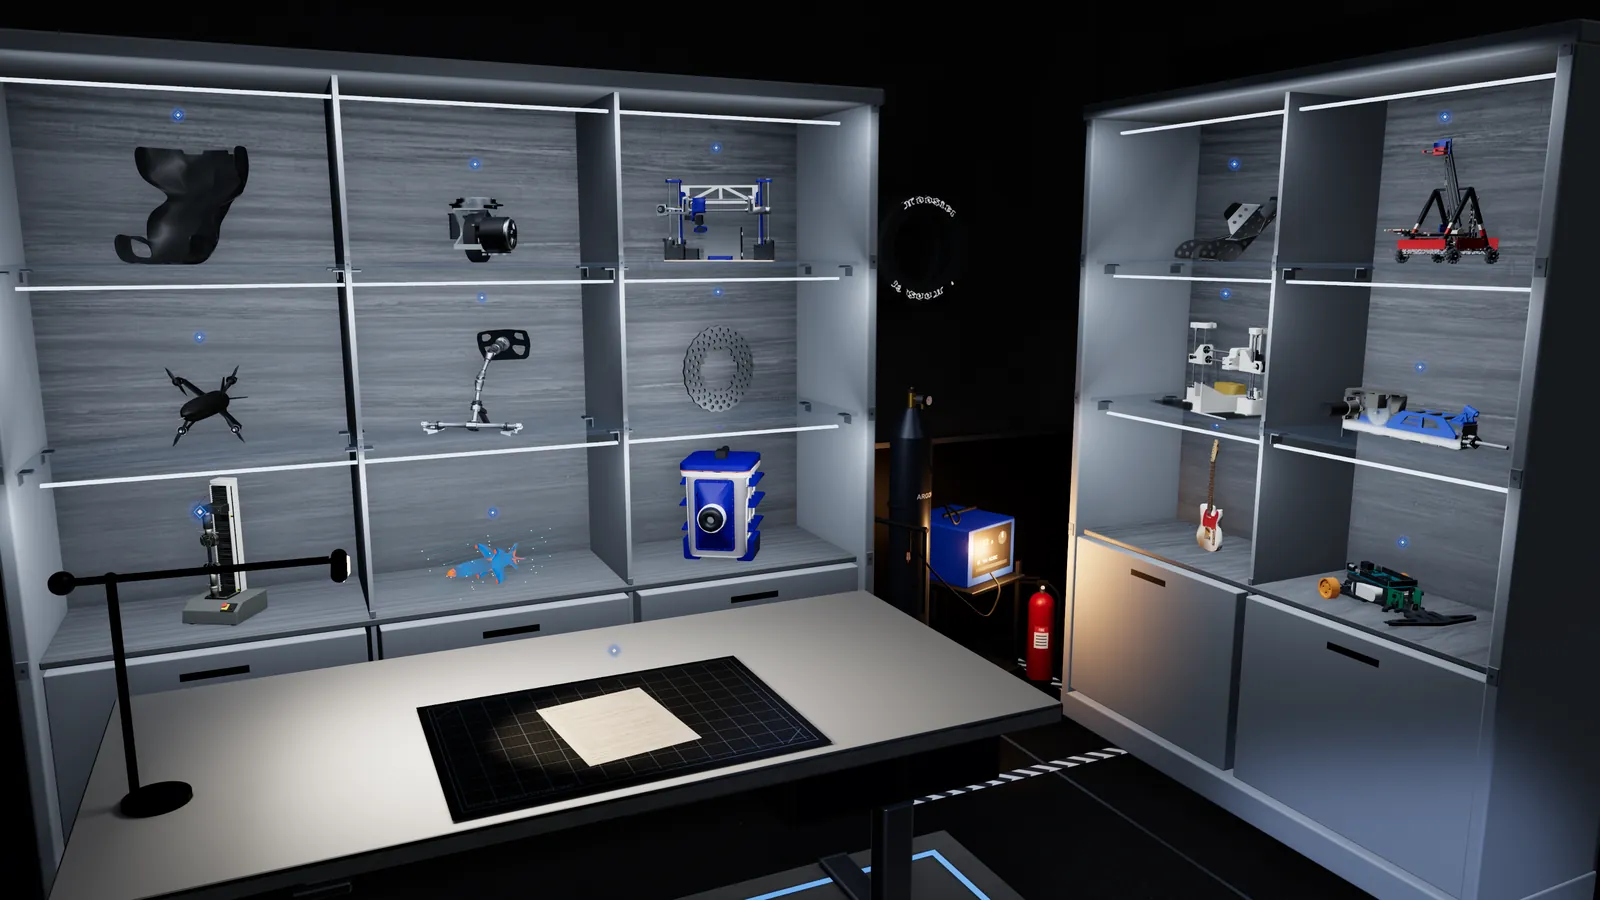
The interactive 3D studio: engineering project models on two lit display cabinets, with the résumé on the desk

03How I work

Own the whole loop.

03

Measure & refine.

Use calibrated sensors and physical tests to challenge the model.

Python · Arduino · Sensors · Testing

Calibration in practice 

04Let’s build something

What’s next
starts here.

Seeking a Summer 2027 internship in vehicle systems, robotics, or manufacturing.